← Daily Brief for October 31, 2026
NVIDIA packages agent harnesses with runtime policy controls
Focus: Technical AI Engineering
Date: October 30, 2026
Topics: Agent runtimes, Policy controls, Harness tuning
Evidence: Publisher Authored
Availability: Available
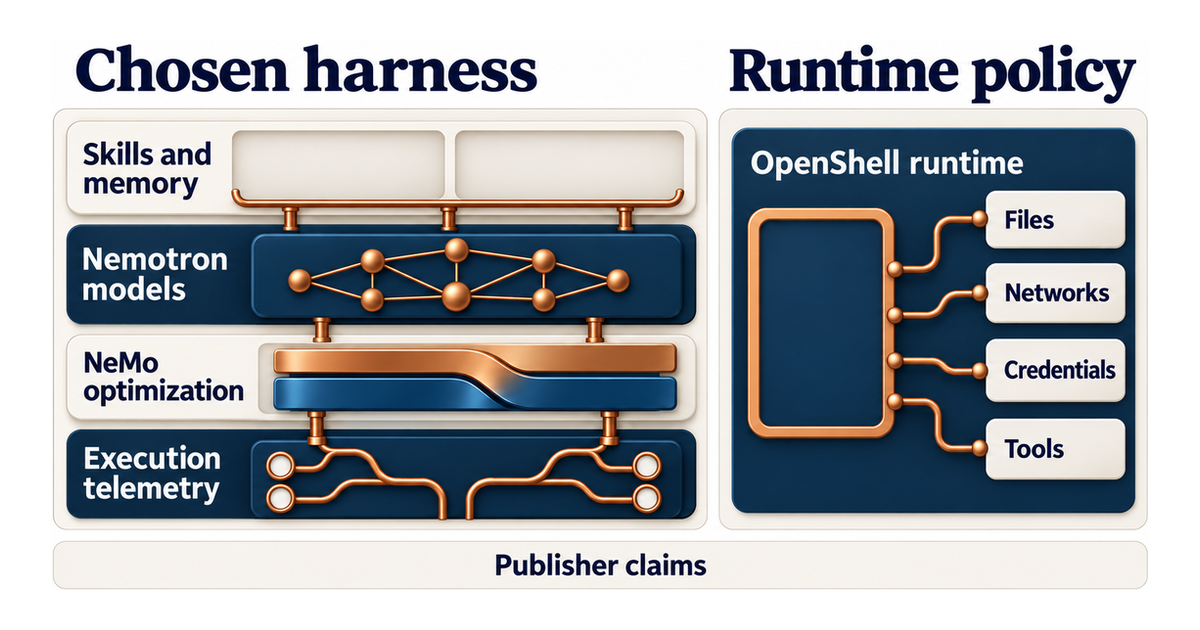
Summary: NVIDIA’s NemoClaw blueprints combine supported agent harnesses, Nemotron models, NeMo optimization and telemetry, and the OpenShell policy runtime. The reference stack can govern files, networks, credentials and tools while retaining a chosen harness. Published cost and performance claims come from NVIDIA and partners, so teams should reproduce them on their own workloads.
Why it matters: Platform teams can compare one existing harness with and without a NemoClaw blueprint, then inspect policy enforcement, credential isolation, traces, task success and cost before treating the packaged stack as production ready.
Source: Build Specialized Agents on a Stack You Control with NVIDIA NemoClaw